Vibration Isolation Mounts for Robot-Mounted Vision Systems
Robot-mounted cameras need isolation mounts tuned to their specific vibration sources.
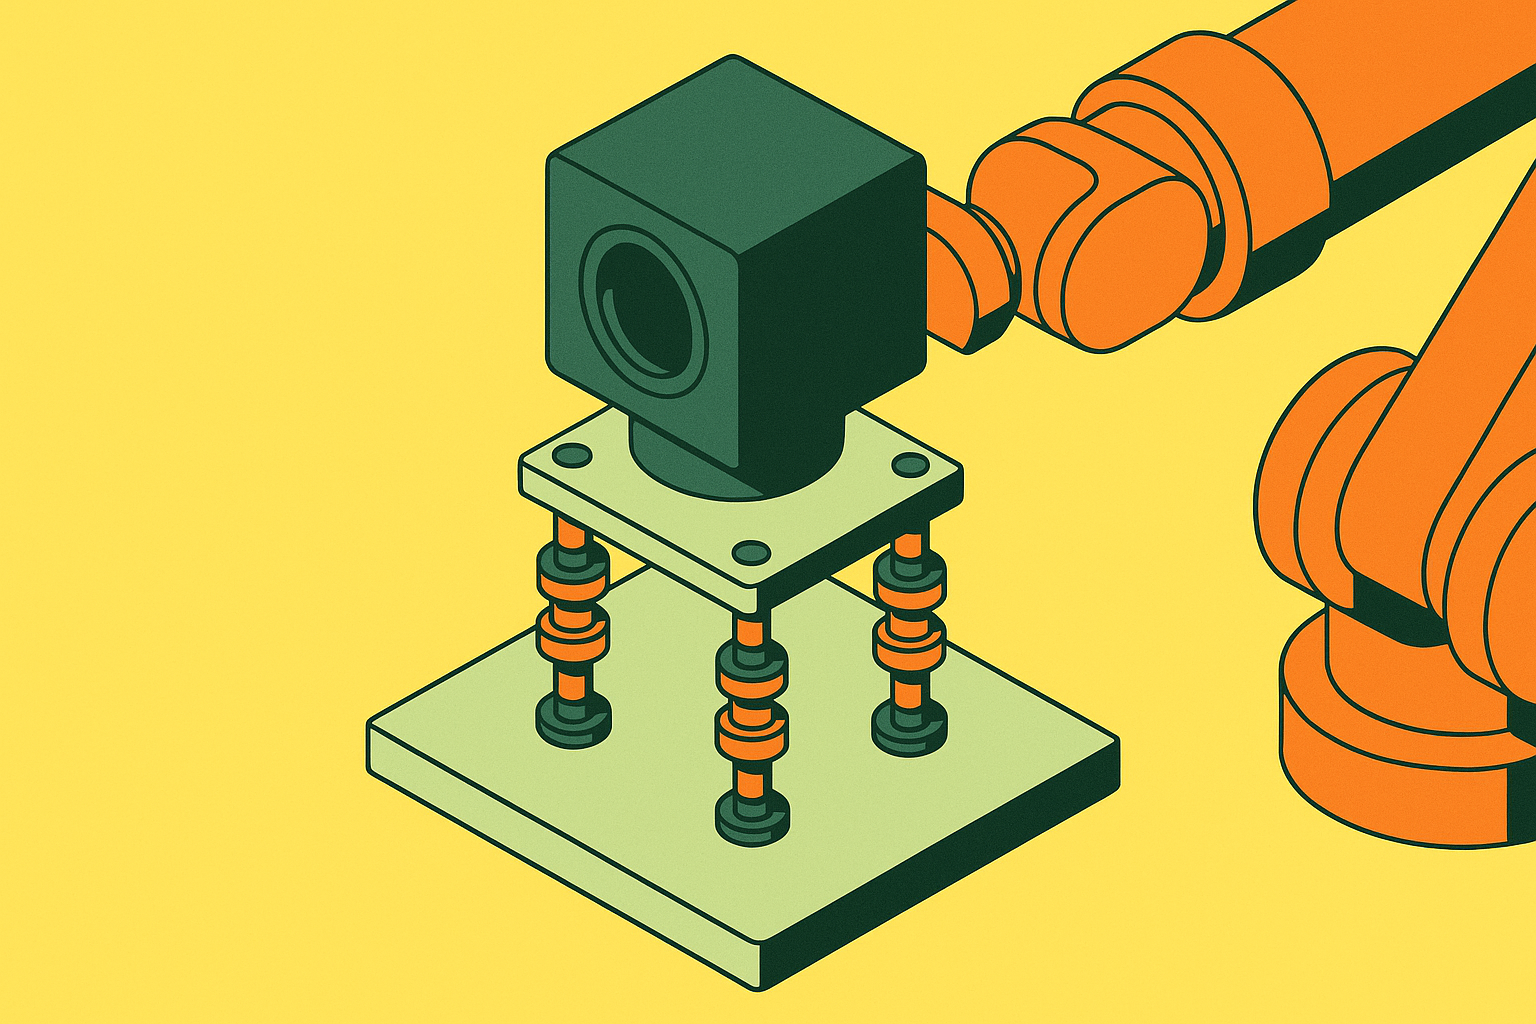
A camera bolted to a robot arm lives inside a mechanical system that never stops moving, so it faces a vibration problem that fixed-mount cameras simply do not have. A fixed-mount camera, bolted to a wall bracket or a stationary fixture, decouples from the equipment around it almost completely. Bolting the camera to the arm itself makes the camera a structural part of the moving system, an observer standing outside it.
The two paths do not behave the same way, and that asymmetry matters for how engineers should think about the problem. Vibration generated by the robot's own actuators, by joint resonances, and by the settle behavior that follows every stop is always present and always co-located with the camera, because the source and the sensor share the same structure. There is no distance to put between them.
This oscillation appears directly in image quality. At sub-millimeter precision targets, the kind of tolerance common in electronics assembly or precision part inspection, a small residual oscillation left over after the robot has nominally stopped is enough to turn a usable frame into a rejected one. High-vibration process environments make the problem worse. In grinding, sanding, welding, and high-speed pick-and-place cells, the robot functions simultaneously as the imaging platform and as the single largest source of mechanical disturbance in the entire work cell.
Vibration transmission through a mount
Engineers sizing a vibration isolation mount for a robot-mounted camera are, in effect, designing a mass-spring-damper system. The camera and its housing make up the mass, the elastomeric element in the mount functions as the spring, and the damping characteristic of that element governs how much the system overshoots when it is disturbed, particularly near resonance. Every mount, understood this way, has a natural frequency: the frequency at which the spring and the mass want to oscillate on their own if left undisturbed.
The quantity that matters for isolation is transmissibility, the ratio of motion delivered to the camera compared to the motion present at the mounting point on the robot structure. Reducing that ratio is the entire point of specifying a mount, and it depends on the relationship between the mount's natural frequency and the frequency of the disturbance trying to pass through it. Isolation only begins once the disturbing frequency rises above the mount's natural frequency. The governing rule of thumb used across vibration isolation engineering holds that the system's natural frequency should be roughly one-third of the disturbing frequency to achieve about ninety percent isolation. The mount has to be specified against the frequency it will face, not chosen by instinct.
Damping shapes what happens at resonance. A well-damped mount controls the amplitude of motion at the resonance peak, and that matters during the start and stop transients that define robot motion. The trade-off is that higher damping also reduces how efficiently the mount isolates once the disturbing frequency climbs above resonance, so damping has to be resolved for the specific application.
Shore hardness, the measure of an elastomer's stiffness, governs both how much load the mount can carry and how much it deflects under that load. Harder compounds, toward 65 Shore A, carry heavier loads with less travel, but they isolate less well. For a vision camera, this trade-off carries extra weight: mount movement during image capture degrades the image just as surely as the vibration the mount exists to absorb, and the softer compound that isolates better can introduce that same problem. Shore hardness selection has to be made for the application at hand, never assumed from a catalog default. Ruland's rubber-jacketed mounts, offered at 55 Shore A, are built around that balance between shock absorption and rigidity, and the same body size is available across three Shore hardness options, letting an engineer change mount performance without redesigning the mounting geometry.
Evaluating a mount for this kind of application means looking at load capacity, natural frequency, performance in both vertical and horizontal directions, damping behavior, geometry, and alignment of the center of gravity together, not load capacity in isolation.
Robot Operating Conditions and Vibration Characteristics
None of the mechanical properties described above can be specified until the vibration source itself is characterized, and that source is the robot cell. The robot's operating speed, the mass of its payload, the dynamics of its joints, and its behavior as it settles at the end of a move all determine the frequencies and amplitudes the mount is actually being asked to attenuate. Skipping this step and reaching for a mount off a shelf treats the specification as generic when it is not.
A typical robot cell has several distinct vibration sources, and each one sits in a different frequency range. Process-induced vibration, the kind generated by grinding, sanding, or welding tool reaction forces, tends to be continuous and broadband, spreading energy across a wide range of frequencies.
Where the camera sits on the arm changes how much of this vibration it experiences. If you mount the camera closer to the wrist and farther from the tool, you shorten the mechanical path between actuator and sensor, so the camera absorbs less stress. The benefit isn't confined to vibration alone: a shorter lever arm also limits how much any residual settle motion gets amplified by distance from the joint, since angular motion at a joint translates into larger linear displacement the farther out it travels.
The arm-mount configuration also introduces a cycle-time constraint that reaches directly into mount design. The robot has to come to a complete stop before the camera captures an image, and any compliance in the mount that extends how long the camera keeps moving after the robot itself has stopped adds directly to cycle time. The damping specified for the mount has to bring that residual motion below the imaging threshold within whatever settle window the application can afford.
High-vibration process environments push these requirements to their most demanding combination. Grinding and sanding cells need a mount that is rigid enough to hold the camera steady during capture but also absorptive enough to attenuate vibration that runs continuously through the process. That combination does not arrive from a default part number. It has to be built from explicit choices about material and geometry.
Mount material, geometry, and hardware interaction with the robot structure
Specifying a mount for this kind of application means resolving four parameters that all interact with one another: the elastomer compound, the Shore hardness, the geometry, and the fastener configuration. Changing any one of them changes how the other three behave, so none of them can be chosen in isolation from the rest.
Elastomer compound selection is driven as much by the chemical environment inside the robot cell as by mechanical performance. Choosing the wrong compound for an oil-present environment does not produce a gradual decline in performance so much as a material that stops doing its job within the application's working life. The metallic core inside the mount carries its own environmental logic: stainless steel resists corrosion, while zinc-plated steel offers higher strength for general-purpose use. Ruland makes both available, and the right choice depends on the specific exposure the cell presents, not on a standing preference for one material over the other.
Geometry determines how the mount handles loading that arrives from more than one direction at once. A robot-mounted camera experiences vibration along all three axes at once, so a mount optimized only for vertical load can still transmit horizontal and rotational motion straight through to the camera even while it looks like it is doing its job on the vertical axis. For high-precision imaging work, that tolerance band has to be folded into the natural frequency calculation for the system.
Fastener configuration needs attention as a systems-level consideration, not a maintenance afterthought. Screw connections that are not torqued correctly, or that lack any thread-locking provision, allow micro-movement right at the interface where the camera attaches to the mount. A mount can be specified correctly in every other respect and still fail the application if the hardware holding it to the camera and the robot is not treated with the same rigor as the elastomer and the core.
Where passive mount isolation is sufficient
Passive elastomeric mounts handle most robot-mounted vision applications well, because the disturbing frequencies typical of robot cells tend to sit well above the range where passive isolation stops working. A passive mount attenuates well once the disturbing frequency rises above its own natural frequency, but it amplifies motion near its resonance peak, and below that peak it transmits motion more or less directly. Above the resonance region, if the mount carries adequate damping, it can handle the isolation job without any active component.
The situations where passive isolation genuinely falls short in this context are specific. Grinding generates continuous broadband process vibration that spans so wide a range of frequencies that a passive mount cannot attenuate all of it unless it goes so soft that it can no longer control camera movement during capture. Applications that need the settle time after a robot stop minimized to hit a cycle-time target push toward a stiffer mount, and a stiffer mount reduces isolation efficiency by definition, creating a direct conflict between throughput and vibration control.
Active isolation systems address these gaps, but they bring real cost. Hybrid approaches offer a middle path: passive isolation handles the higher frequencies, and active control is reserved for the lower-frequency resonance region where passive mounts amplify rather than attenuate, without requiring a fully active system across the whole bandwidth.
The decision rule that follows from this is straightforward to state and easy to skip in practice: characterize the disturbing frequencies in the cell first, then check whether they fall inside the range where passive isolation works, before specifying any active component. Passive mounts are not a universal answer, and active systems are not an automatic upgrade. Each is the right tool for a specific frequency range, and the frequency data decides which one applies.
How software triggering and IMU-gated capture complement mount selection
Deterministic image capture, triggering the camera only once the robot is confirmed stationary and synchronizing that trigger to the PLC through a hardware signal, is standard practice in robot-mounted vision systems, and it reduces the share of frames degraded by robot motion. Hardware triggers tied to PLCs already coordinate reject gates and pick-and-place operations across a robot cell, and the same synchronization signal can be used to gate image capture until the robot has settled. The limitation is that this method addresses blur at the moment of the trigger but says nothing about residual vibration that continues afterward. If the camera is still oscillating on a compliant mount when the trigger fires, the resulting image is degraded regardless of how precisely the trigger was timed to the robot's stop command.
IMU-gated imaging offers a complementary approach. This method does not require the robot to be fully settled before it works. The trade-off is added latency and added complexity in the image acquisition pipeline, and the quality threshold used to accept or reject a frame has to be tuned carefully: set it too tight and throughput suffers, set it too loose and degraded frames pass through anyway.
High-frame-rate camera-based vibration monitoring adds a diagnostic layer on top of both approaches. If you use the vision camera itself to record robot vibration at 1,000 frames per second, then decompose that footage into individual frames for frequency analysis, you get a direct measurement of the vibration environment rather than an estimate drawn from the robot's published specifications. That measurement can then feed back into mount selection, closing the loop between how the vibration was characterized and how the mount was specified.
None of this makes software a replacement for a correctly specified mount. Triggering and IMU gating reduce the consequences of vibration at the instant of capture, but they do nothing to reduce the vibration itself. A poorly specified mount that allows large-amplitude camera oscillation after the robot stops forces a choice between long settle delays that hurt cycle time and degraded frames passed through anyway. A well-specified mount shrinks the problem that any software layer, whether a hardware trigger or an IMU gate, has to manage, so the software works better.
A practical specification sequence for engineers selecting mounts for robot-mounted cameras
Mount selection for a robot-mounted camera should follow the same structured sequence used for any other vision system component: characterize the requirement, derive the specification from that characterization, select hardware to meet the specification, then validate the result in the installed configuration. Treating mount selection with less rigor than lens selection or exposure settings leaves a gap in a system otherwise built to tight tolerances.
The first step is characterizing the vibration environment itself. That means identifying every vibration source present in the cell, including the robot's own actuators, any process tools doing the work, adjacent equipment, and the facility floor beneath it all. And it means measuring or estimating the amplitudes involved, asking directly whether the application demands sub-millimeter localization precision and, if it does, what amount of camera motion at the moment of capture the system can actually tolerate.
From there, the mount's natural frequency target follows from the one-third rule described earlier, checked against the Shore hardness, geometry, core material, and fastener configuration appropriate to the specific cell, its loads, and its chemical environment. Selecting a mount this way treats it as what it actually is: a working part of the vision system, specified with the same care given to the camera's optics and timing, not an accessory chosen after the real engineering is already done.